Selected work
Research & engineering / Shi Che
From an idea to a mechanism.
From a model to a working system.
A closer look at what I designed, built and contributed: robotic systems, composite structures and the tools that connect models to the physical world.
Built & implemented
Robotics, research data and composite engineering.
Robotics · System integration
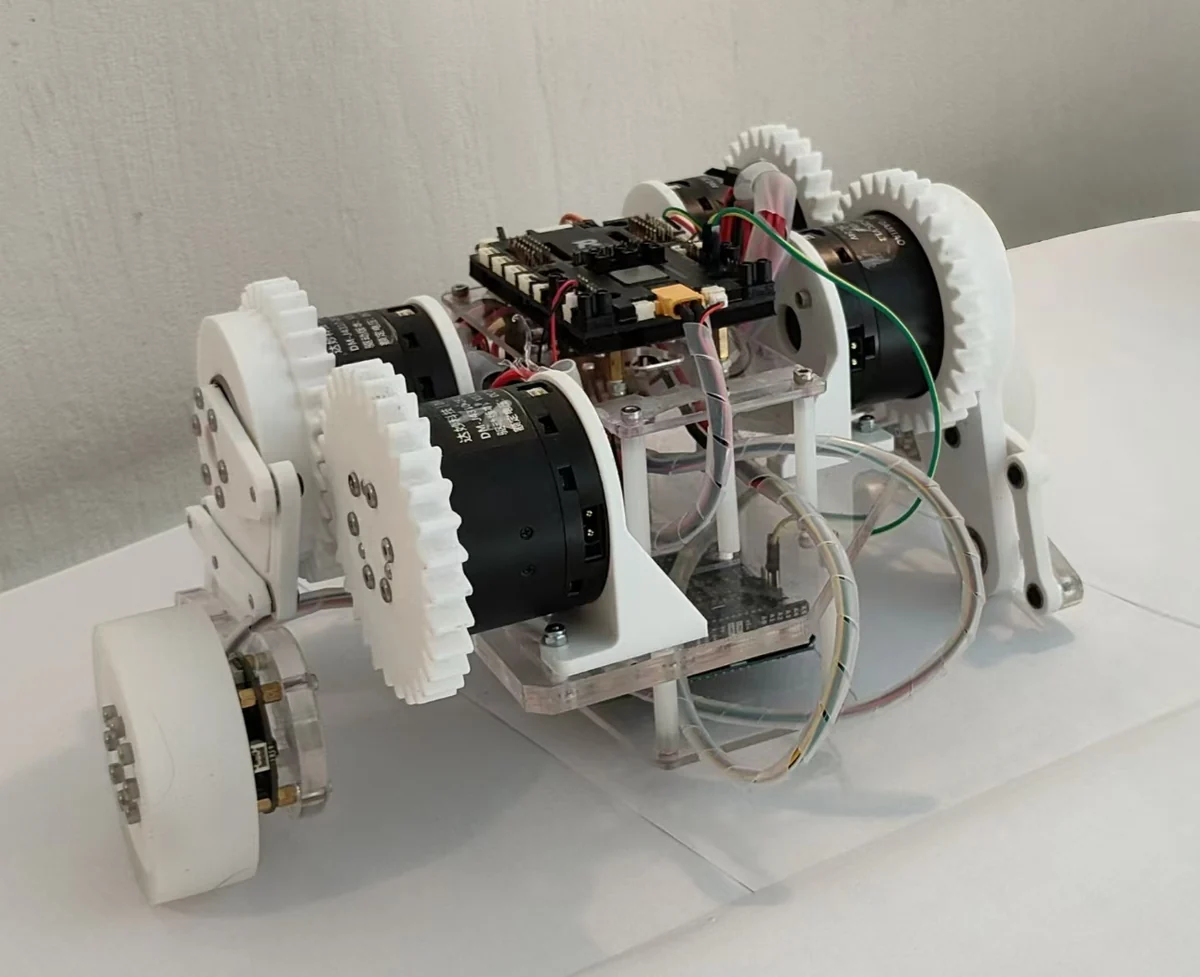
SparkR
A compact wheel-legged platform that brings mechanism design, custom electronics and balance control into one working prototype.
My role
Independent mechanical, electronics & control development
Research · Robot data
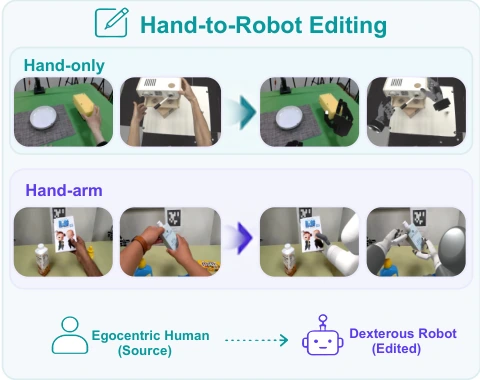
HandEdit
Robot asset standardization and an EgoDex processing pipeline contributing approximately 190M editing instances to HandEdit.
My role
Fifth author · robot asset standardization & EgoDex processing
Mechanical design · Manufacturing
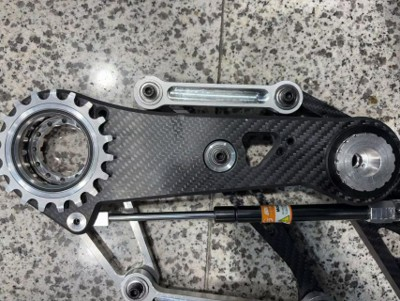
RoboMaster leg mechanism
A hollow carbon-fiber leg developed through structural comparison and manufacturing iteration for a balance-infantry robot.
My role
Leg subsystem design & manufacturing
Simulation · Engineering tools
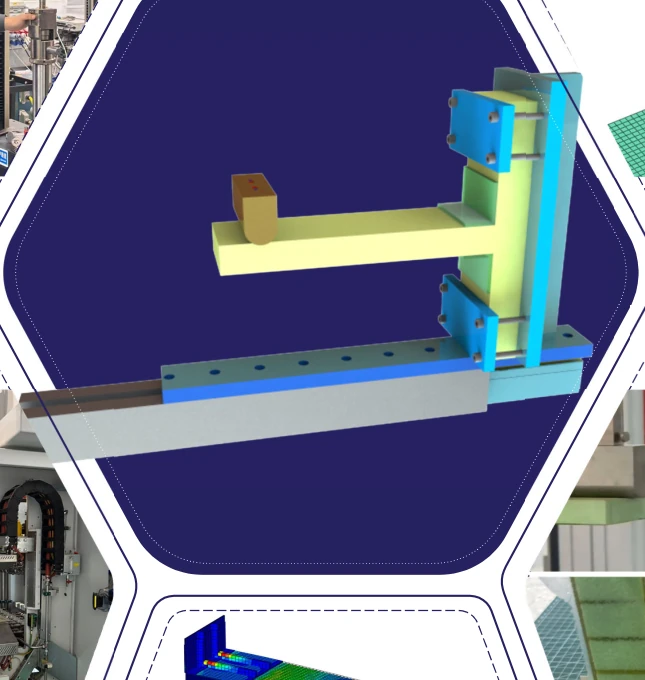
Composite modeling automation
Abaqus Python scripts for comparing composite layup, angle and thickness through repeatable finite-element studies.
My role
Abaqus Python automation & design comparison
On the workbench
Mechanical design for interaction and service robotics.
Embodied interaction · Mechanical assembly
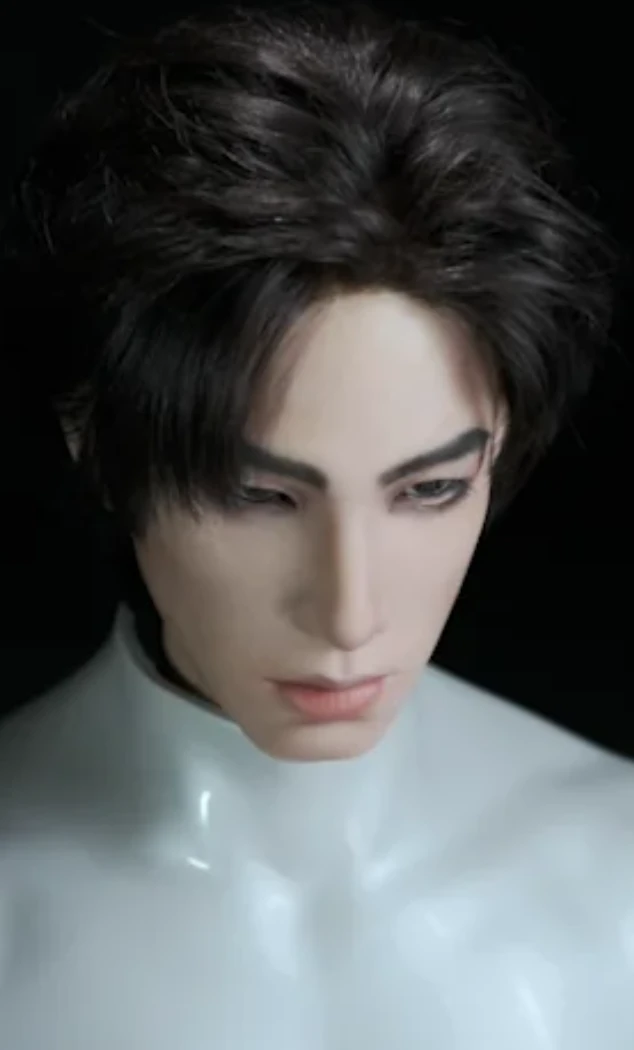
深穹星核 · Embodied interaction
Internal assembly and mechanical design adjustments for Novacore’s expressive-face platform, within the 深穹星核 project.
My role
Core team member · internal assembly & design adjustments
Service robotics · Chassis design
Tennis ball-service robot
Overall wheel-legged chassis design for a tennis ball-service robot in a Jiaolong × Lumistar collaboration.
My role
Overall wheel-legged chassis design · Jiaolong × Lumistar collaboration