HandEdit
Research · Robot data / Jan–Aug 2026
Consistent robot embodiments for egocentric image editing
CompletedFifth author · robot asset standardization & EgoDex processing
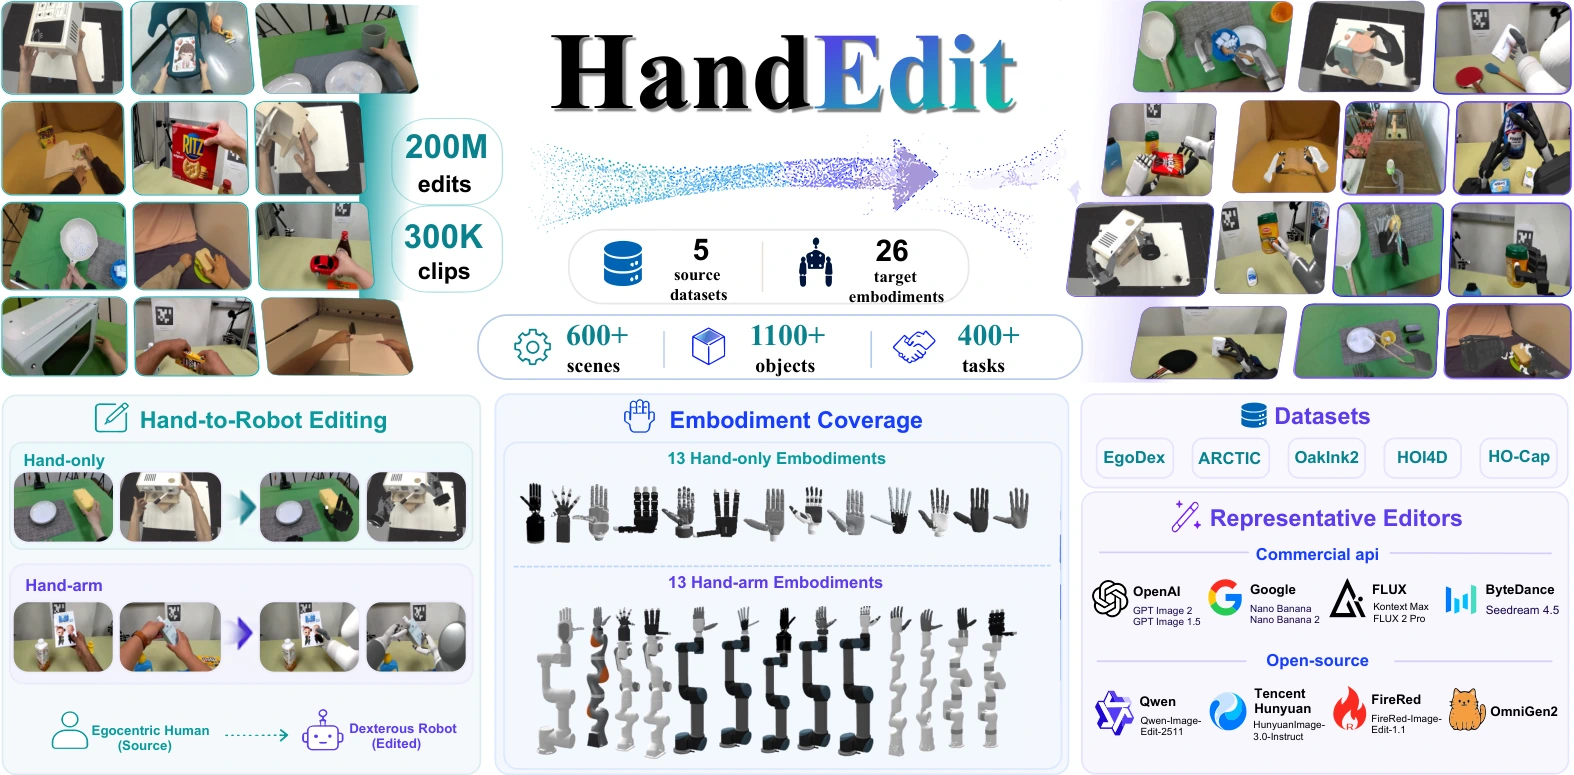
As fifth author, I selected robot embodiments, standardized multi-configuration URDFs, configuration files and materials, and built the EgoDex processing and conversion pipeline. This pipeline produced approximately 190M editing instances—about 95% of the project’s 200M edits, by my own count.
Project goal
HandEdit replaces human hands with robot embodiments in egocentric images. My work connected consistent robot assets with the EgoDex processing workflow for large-scale data generation.
Design choices
Choose compatible embodiments
Consider degrees of freedom, kinematic reachability and morphological diversity when selecting arm and hand combinations.
Standardize the assets
Organize URDF links, joints, configuration and materials consistently across robot embodiments to support batch rendering.
Connect data transformations
Build the EgoDex conversion workflow linking background inpainting and robot-hand retargeting for the team data-generation process.
Development
Embodiment selection
Compare candidate arm–hand combinations against representation and kinematic needs.
Asset preparation
Unify model structure, configuration and material conventions.
Pipeline integration
Connect the standardized assets to the EgoDex conversion workflow.
Gallery